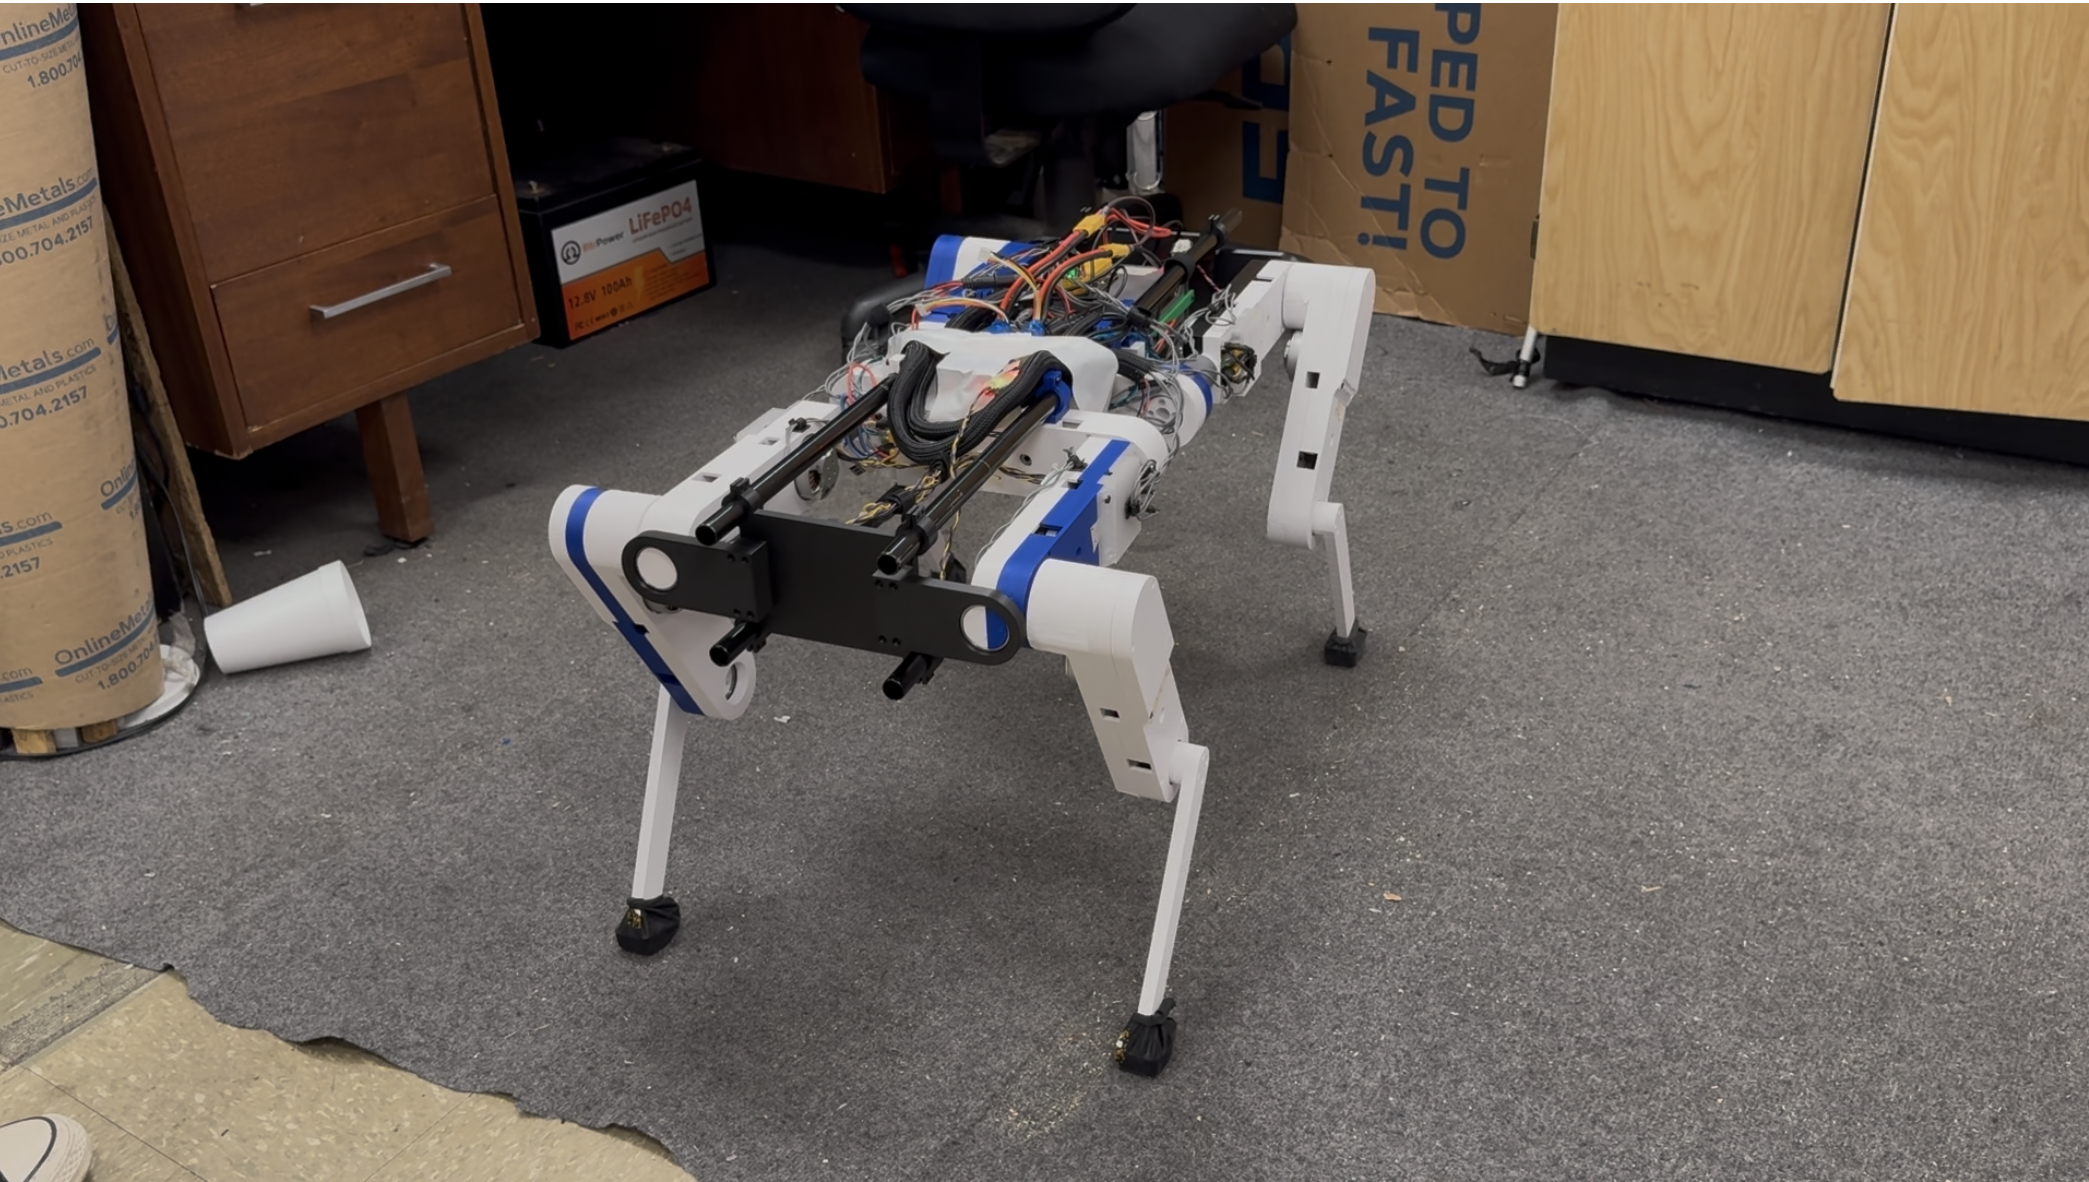
This project was a year-long journey for my senior design class (EGEC 499), where I got to collaborate with three very talented engineers. I worked on the motor controller interfacing, as well as the interprocess communication across the sensors and main computer.
Highlights
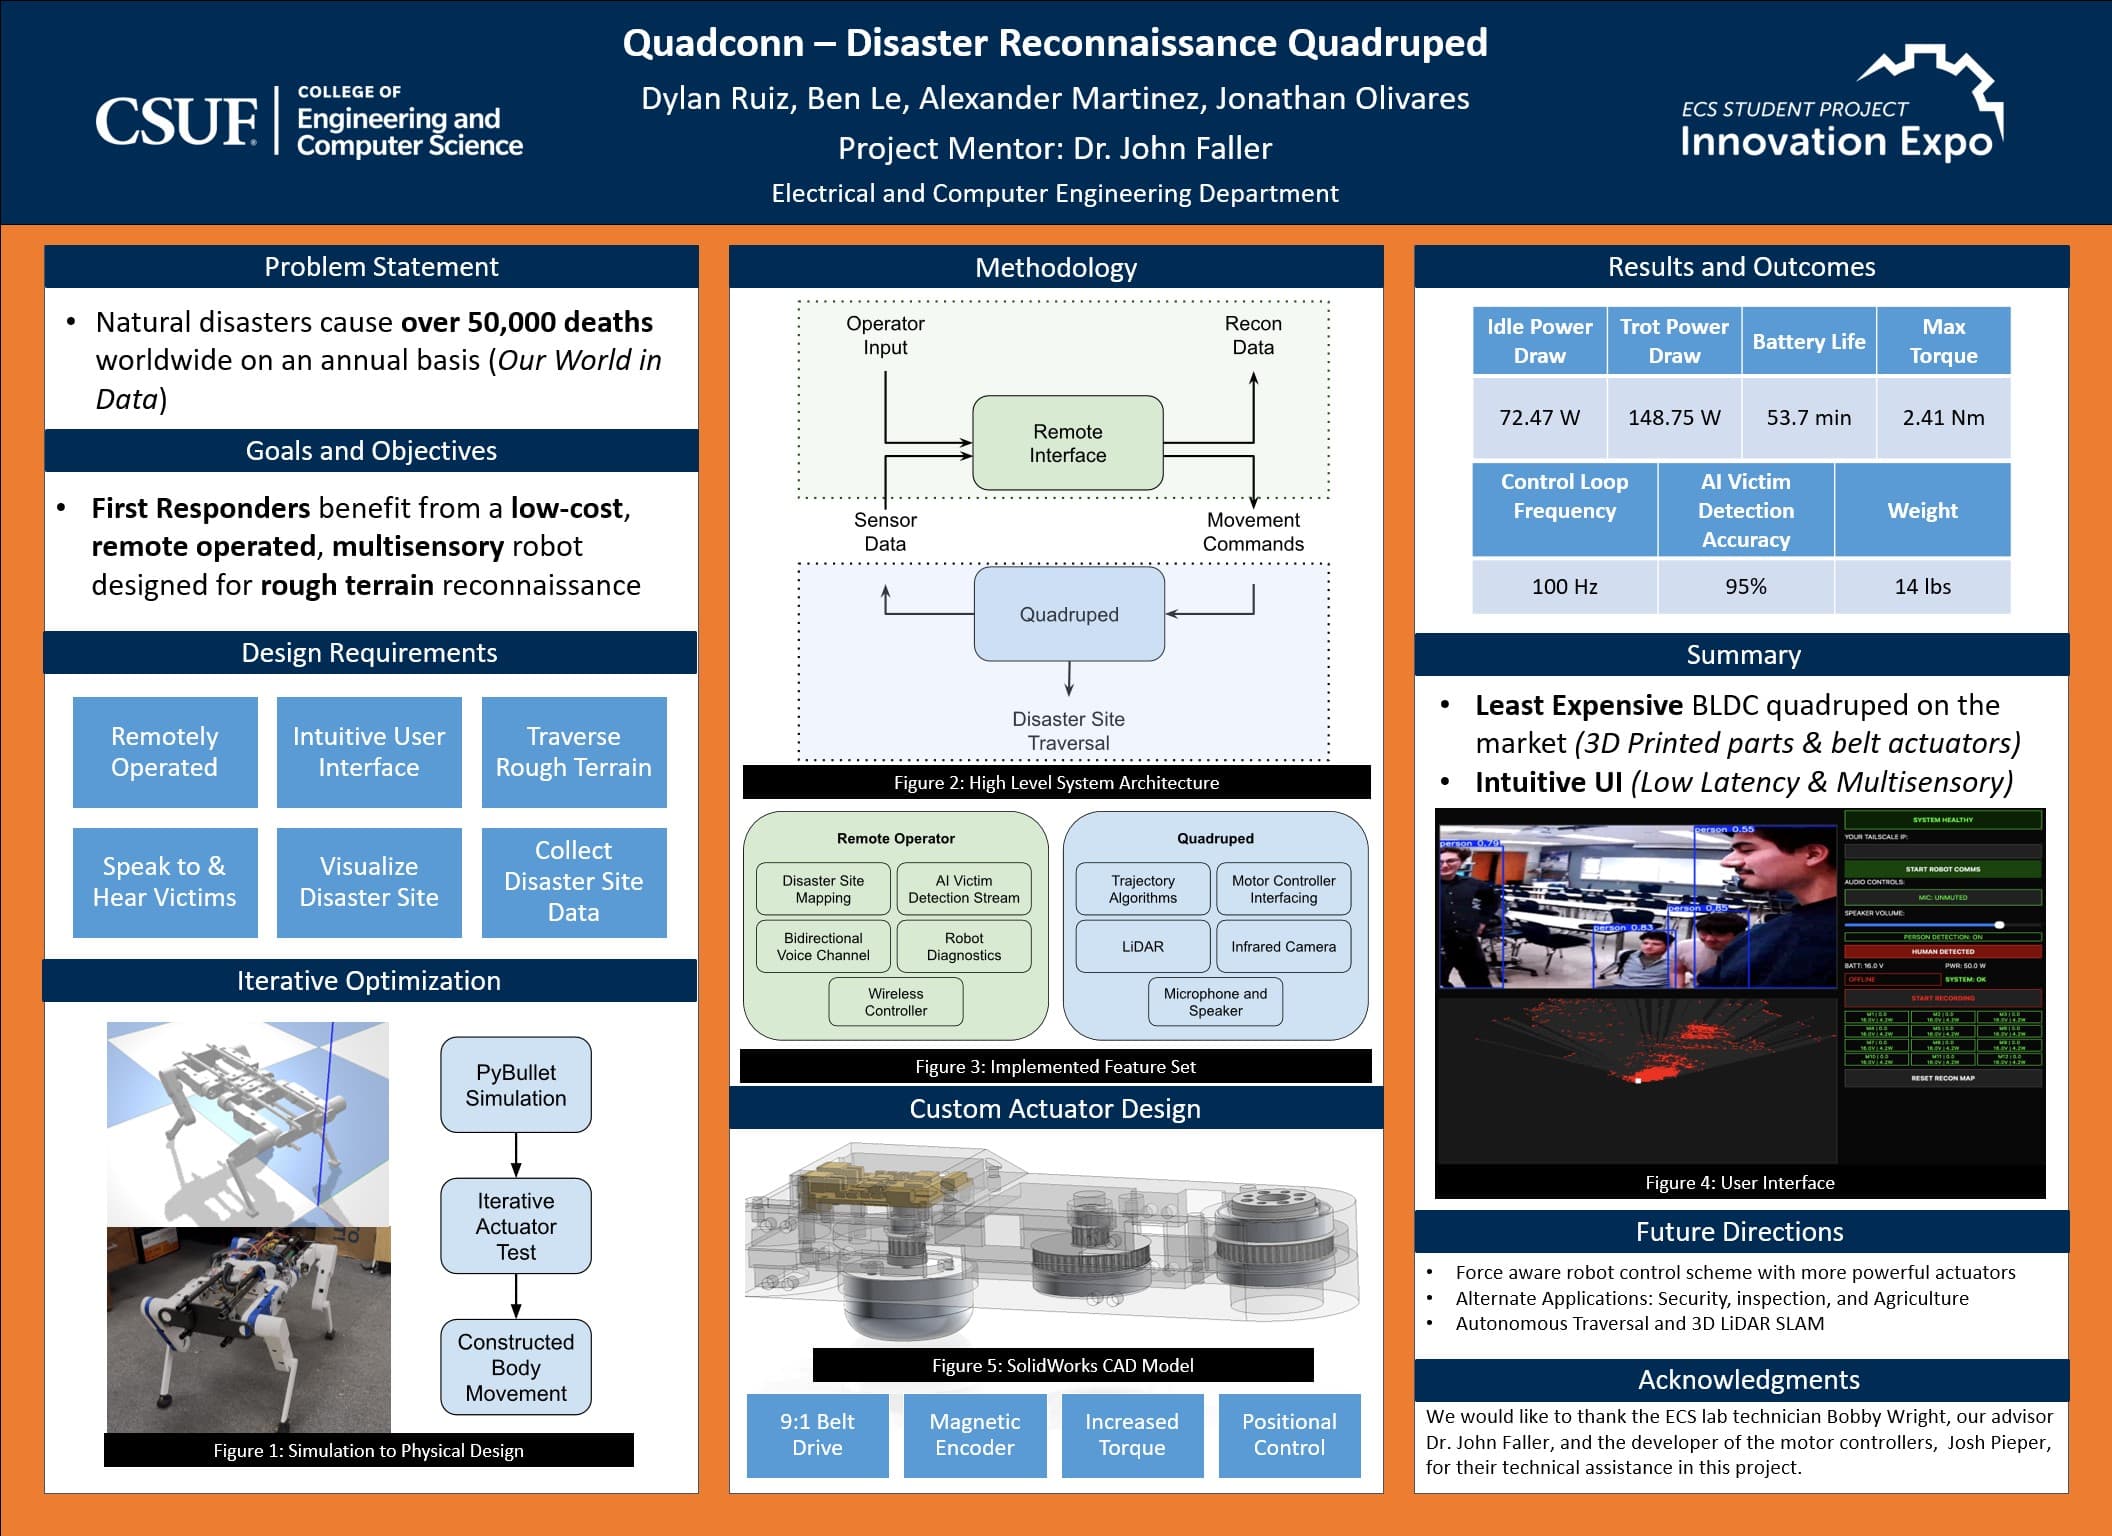
- Under $2k Budget with 12 degrees of freedom
- Bi-directional audio, intuitive controls, live video feed with human detection
- custom actuator design using a two-stage 9:1 gear reduction
Something significant that I would've never thought to appreciate was using Git as actual version control instead of a glorified Dropbox for code. Using the branching feature, especially when collaborating with several other people trying to push code and test, made my life so much easier.
I also got to develop a new-found appreciation for technicians. Given that our team was only four people strong, I was responsible for doing the routine electrical work, crimping CAN connectors, soldering leads onto the motor controller boards, and ensuring that the wiring of the boards didn't end up with all of the boards burning up due to a reverse polarity connection. Soldering was an especially fun skill to me, and I hope that I get to use it a lot more in the future (my wishes came true in the TENS unit project).
Demos
Awards
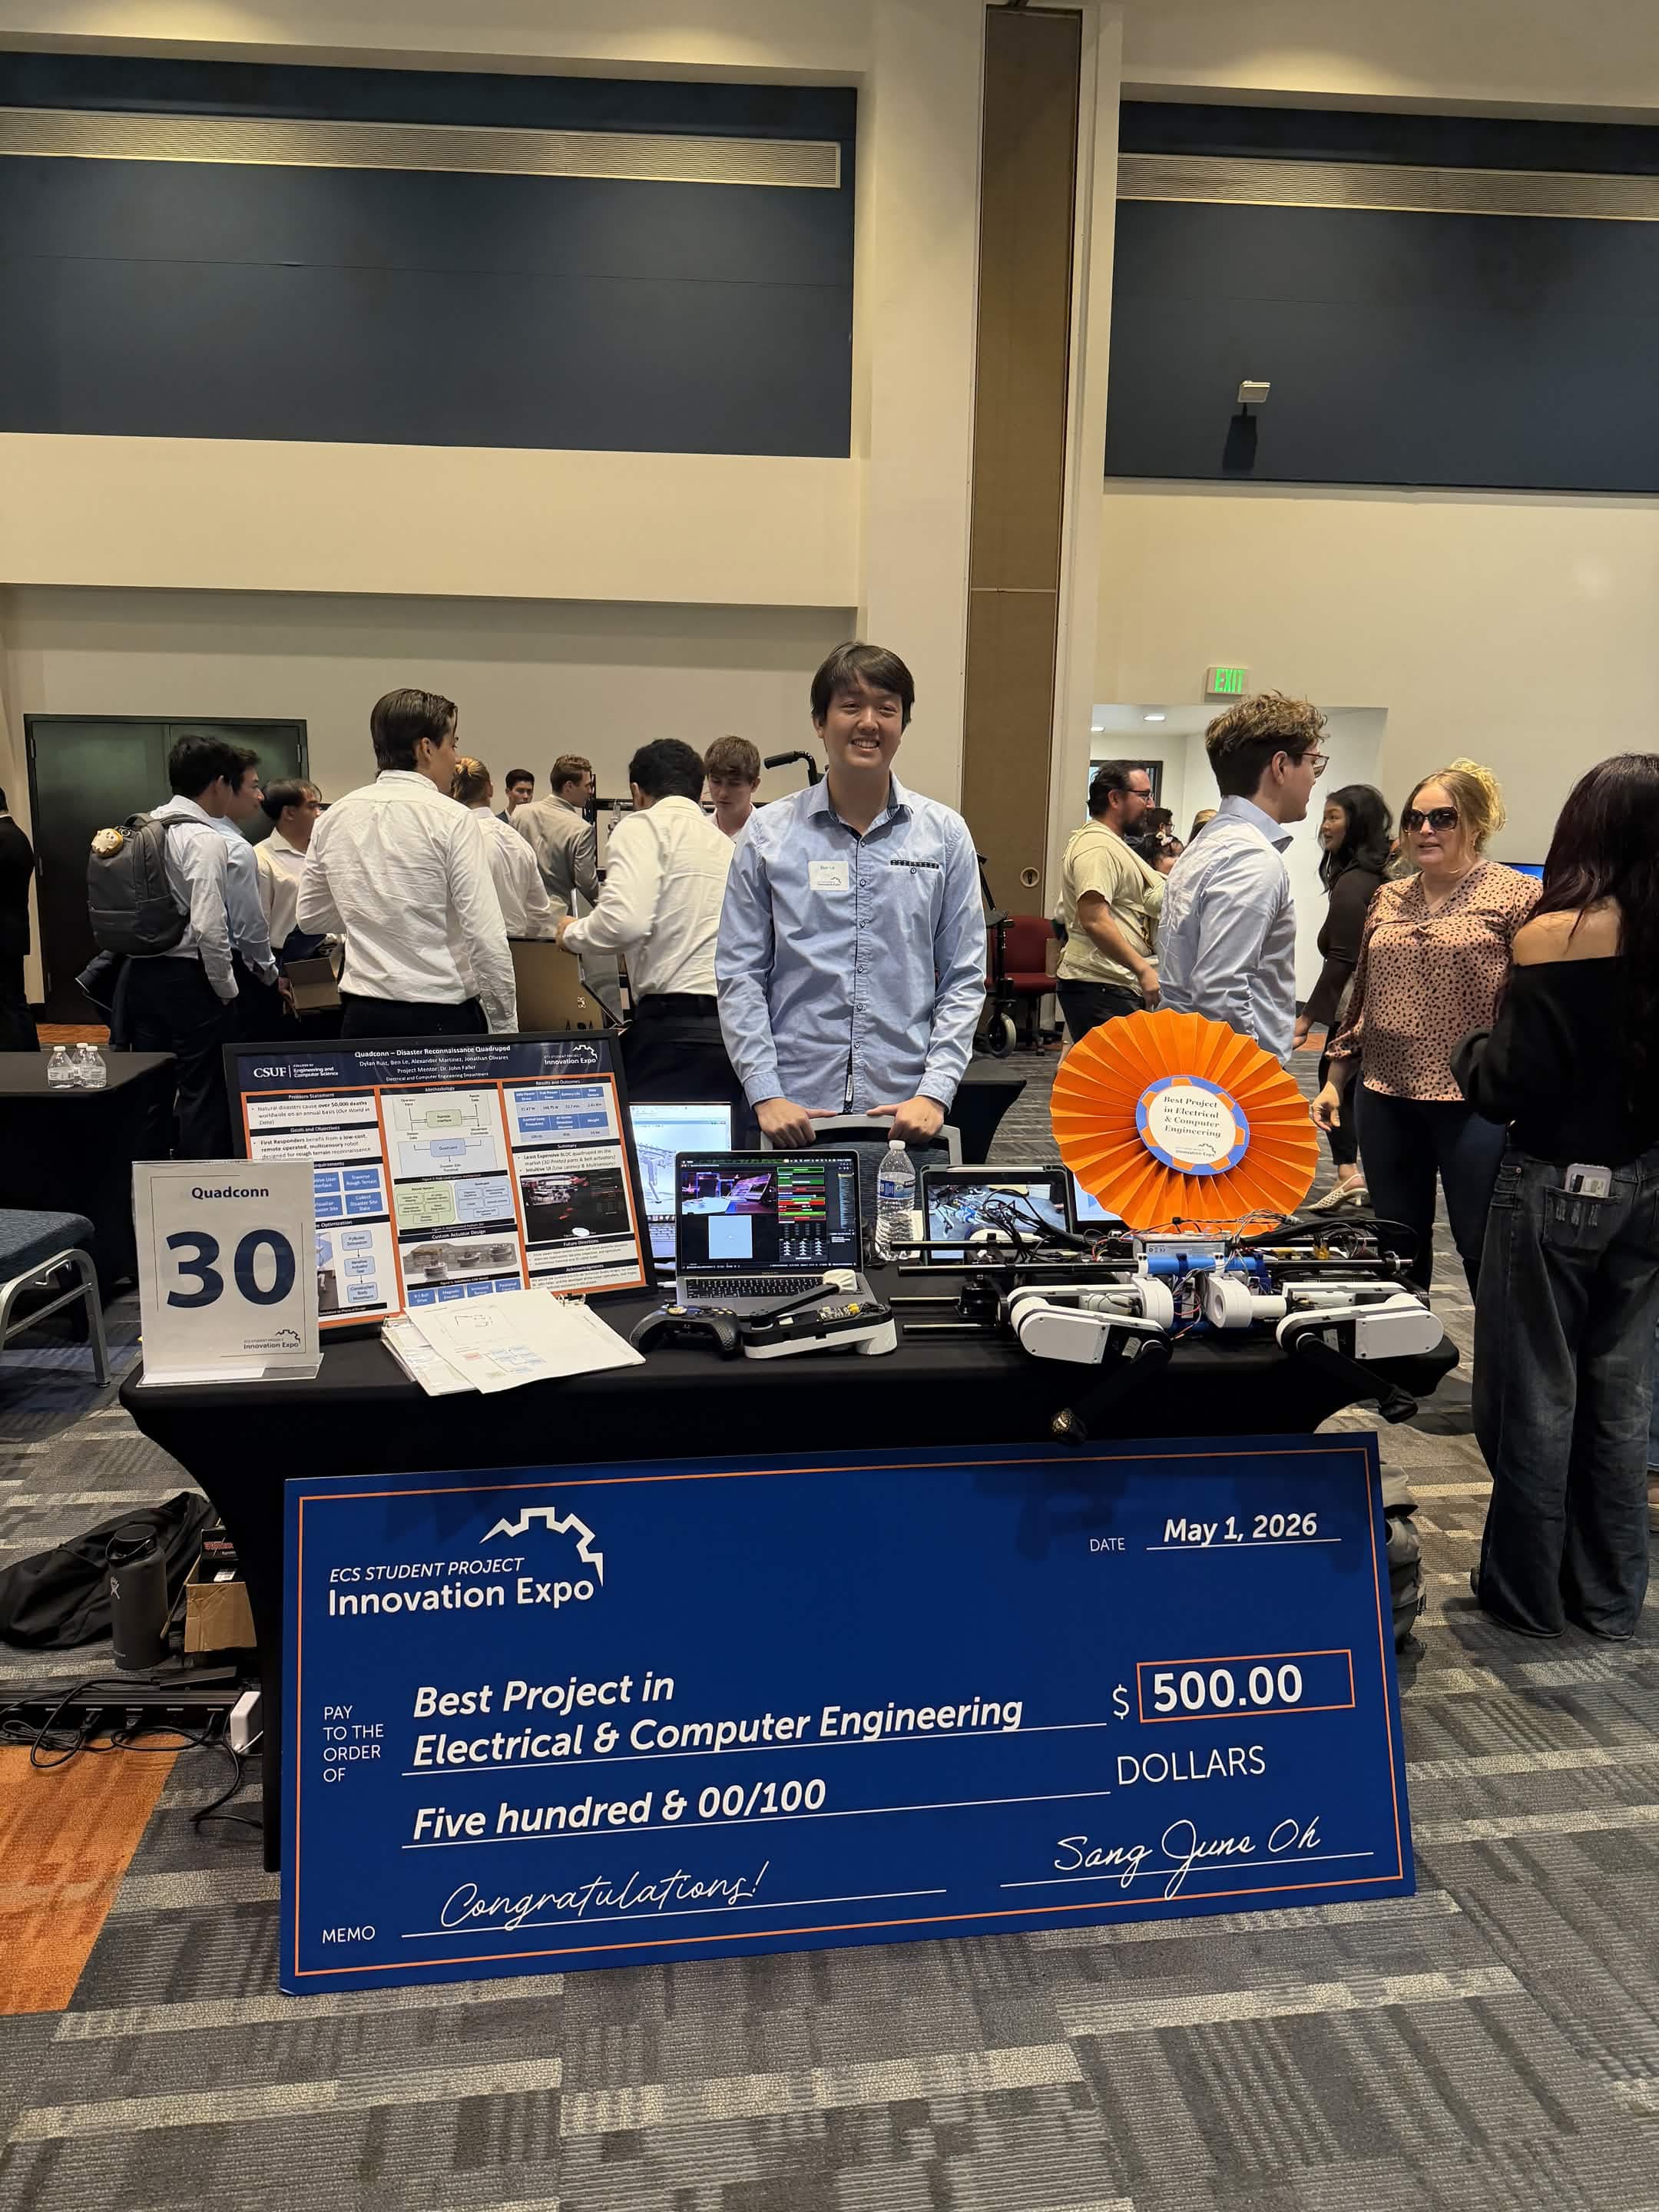
At the 2026 CSUF Innovation Expo, our team won $500 for being the best project in the electrical and computer engineering department. It was a hard-earned award, and I couldn't have done it without the help of my team.
Notes
This project utilized iceoryx2's zero-copy publish-subscribe model for the majority of its processes. A link to the repo can be found here.